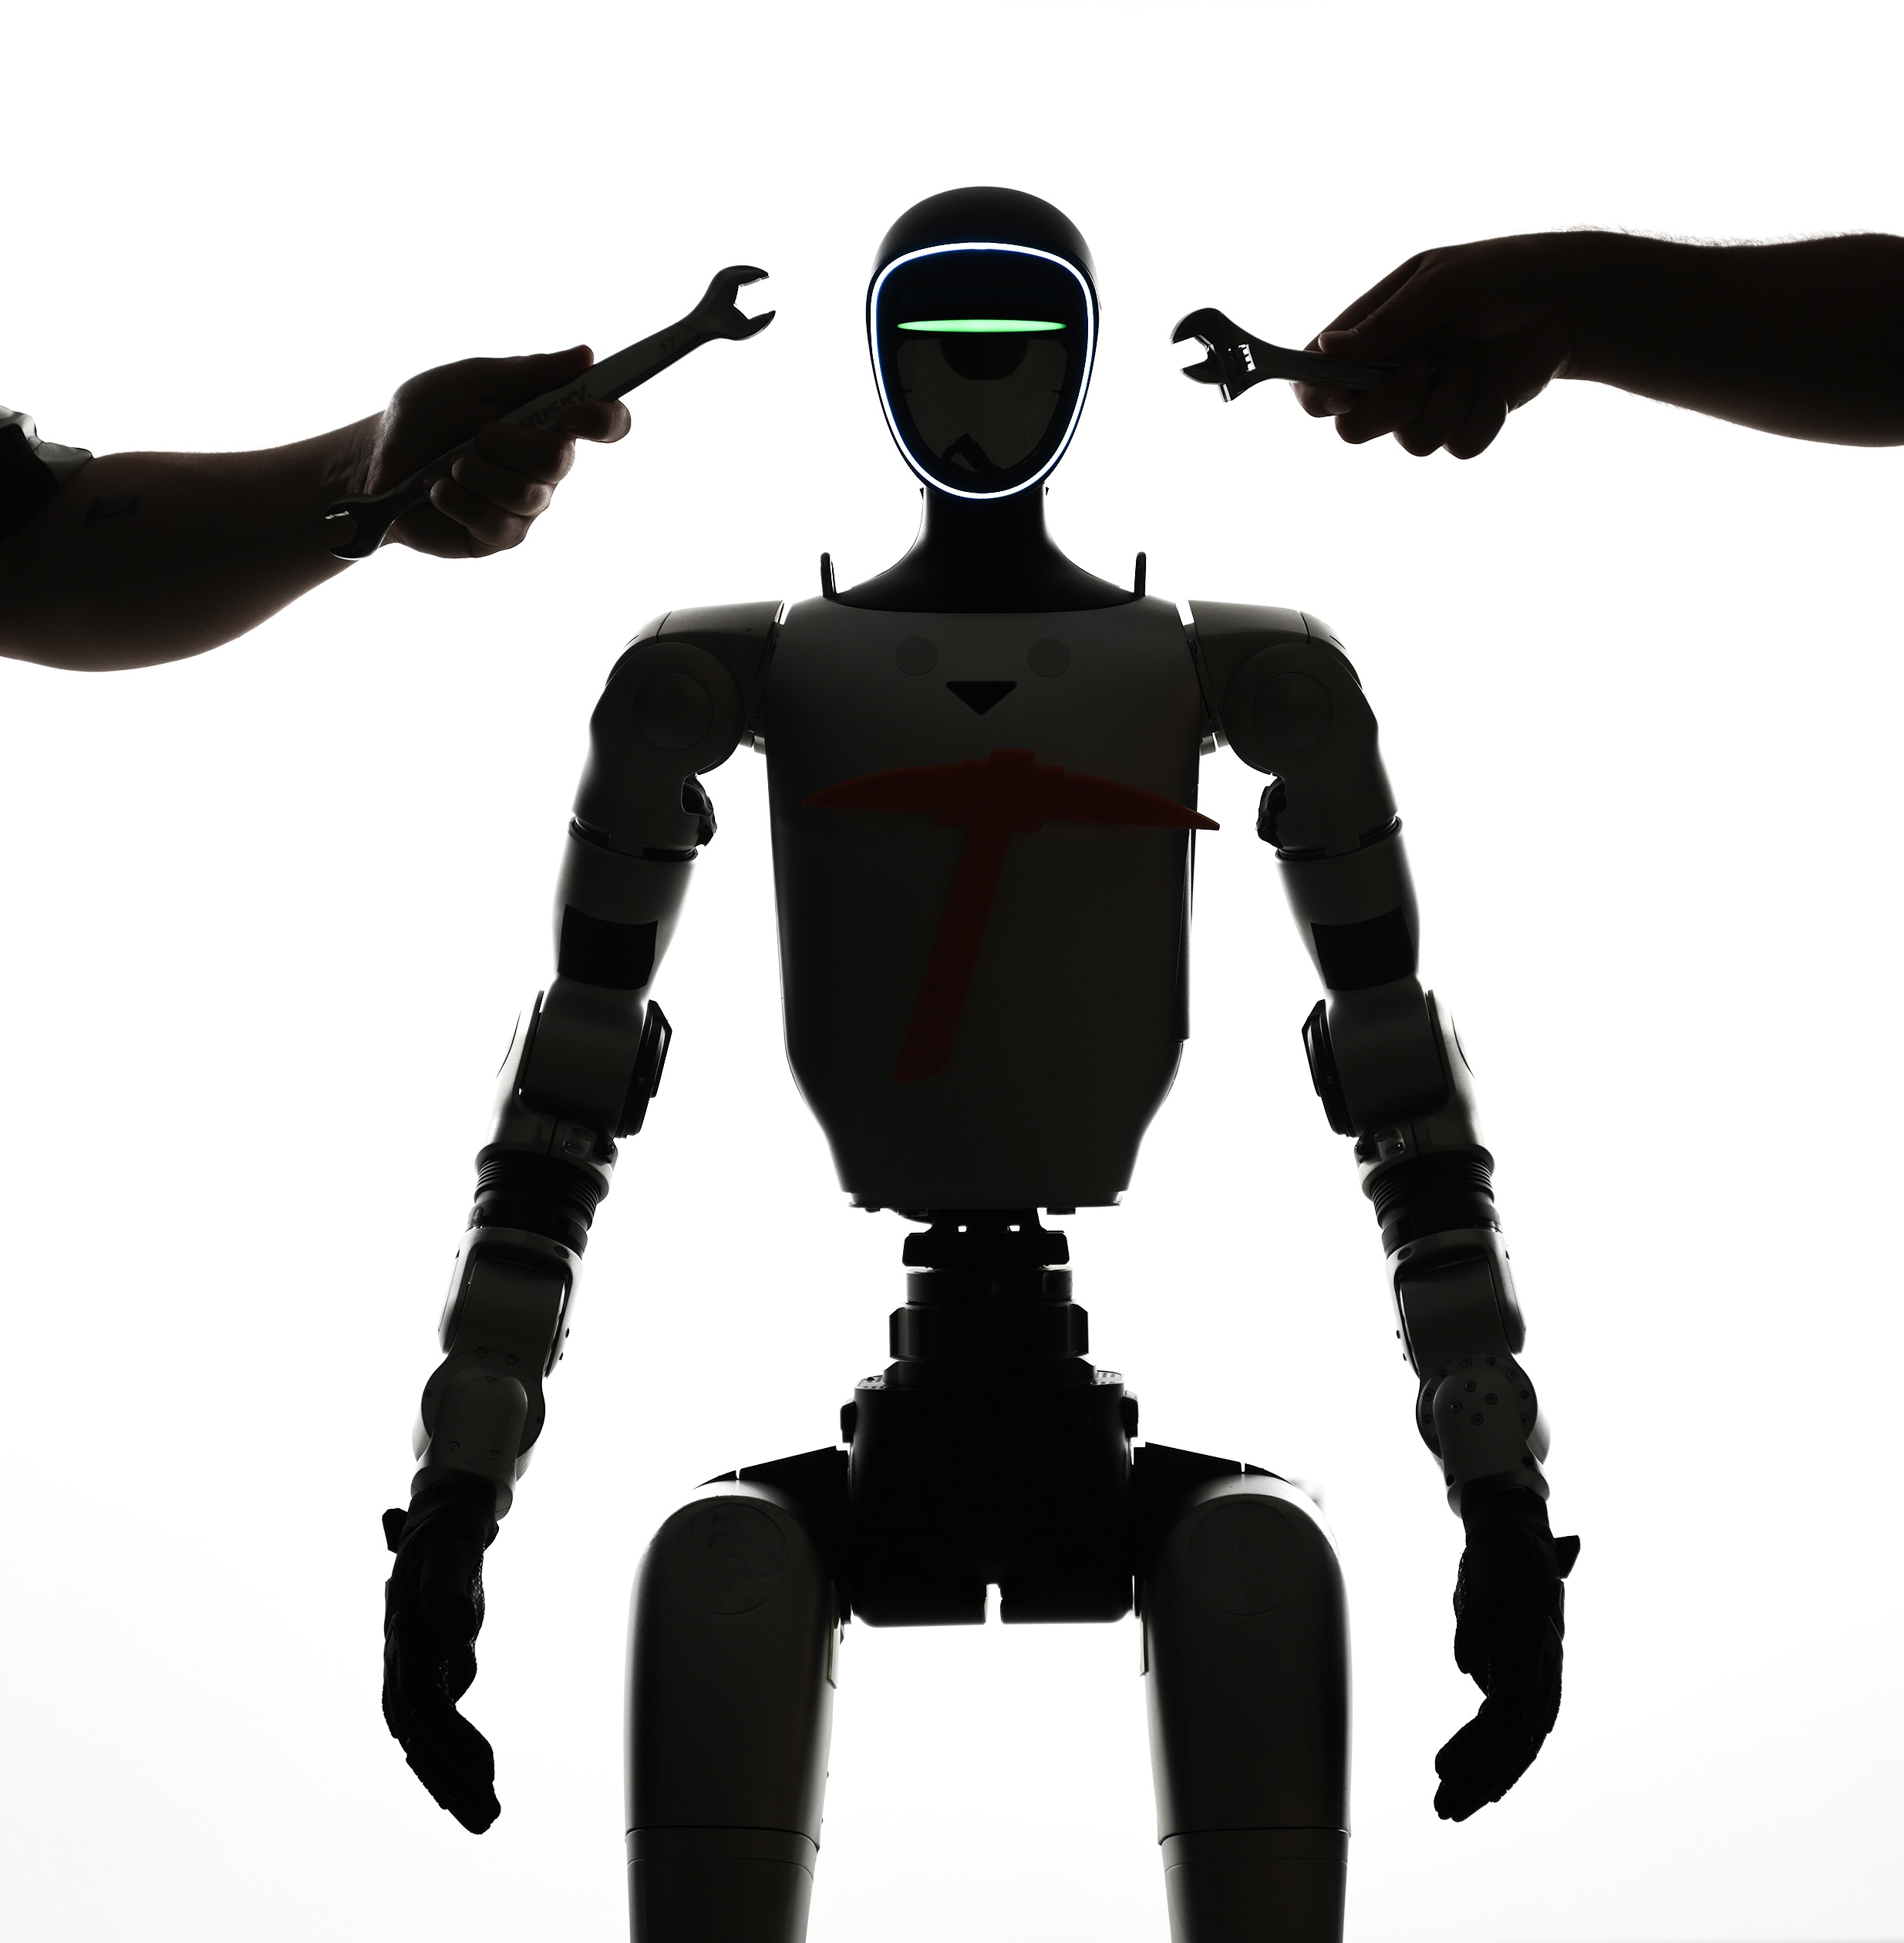
Architecture of Intelligence for Gaits and Integrated Systems (AIGIS in short) Lab at The University of Texas at El Paso (UTEP)
advances the foundations of safe and intelligent robotic autonomy.
We integrate control theory, optimization, and embodied AI, including reinforcement learning, to enable robots to move dynamically, adapt to uncertain environments, and cooperate safely with people and other robots.
Our research bridges theoretical advances with real-world experiments in agile legged locomotion, whole-body coordination and manipulation, and distributed planning and control for multi-robot systems.